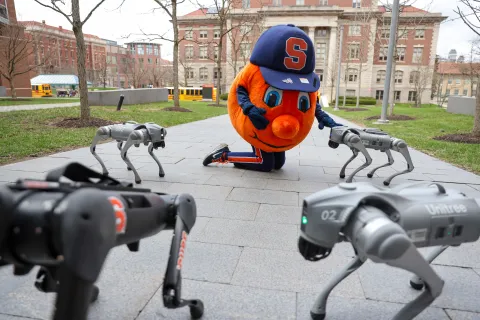
ECS researchers are engaged in the exciting field of robotics and controls. Significant contributions have been made in a wide range of theoretical, computational and experimental research areas. These research activities will help improve the sustainability, intelligence, and resilience of critical infrastructure and systems that are vital to the well-being of our society.
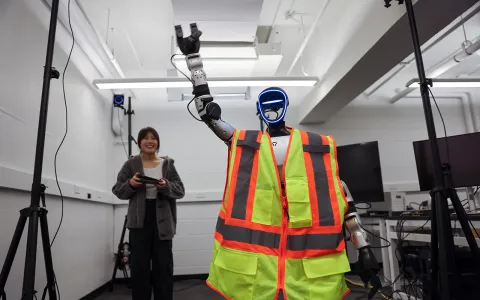
Theoretical research in this area includes nonlinear geometric control theory, nonlinear adaptive control theory, hybrid dynamics and control for legged robots, data-driven control methods, and distributed control of multi-agent systems. Computational and experimental research is being carried out on applications such as smart drones, unmanned aerial vehicles, spacecraft, legged robots, robot-assisted rehabilitation, soft robots, intelligent control of built environmental systems, and other cyber-physical systems, as well as high-speed flow and unsteady aerodynamics.